Know your robot is ready before it ships.

We build site twins of your customers’ real locations, sim-ready assets and generated environments, all physics-ready for your robots to work in.

Hyperverse is a Physical AI simulation infrastructure company, building digital twins, sim-ready assets and generated environments so robot teams can rehearse a deployment before anyone travels.

What we build

  1. 01Per siteSite twinsA real customer site, captured in person and rebuilt as a photoreal, physics-ready scene.
  2. 02Per objectSim-ready assetsSingle objects with collision geometry and tuned physics, rigid or deformable.
  3. 03Per sceneGenerated environmentsFully interactive, physics-aware scenes we build from a prompt, images or a video.

01Site twins

Every new customer site is a site your robot has never seen.

Your customer’s real site, captured in person and delivered as a photoreal, physics-ready USD scene for Isaac Sim.

Browse the arenas catalog

From a real site to a robot at work in its twin.

A yard bay, captured, rebuilt, fitted with assets, then worked by a forklift.Building materials yard

How it works

  1. 01

    Capture the site

    We capture the work area on site, or guide your team through a phone scan for smaller spaces.

  2. 02

    We build the twin

    We reconstruct the site and make its assets interactive and physics-aware. Our team assembles and checks the splat, collision, scale and physics.

  3. 03

    Rehearse in Isaac Sim

    You open one USD file and run your task: your robot model, in the real layout of the site.

02Sim-ready assets

Objects that weigh, slide and bend like the real thing.

Send a photo, a video, a prompt or a GLB. We deliver a USD asset with collision geometry, tuned mass and friction. Rigid by default, deformable on request.
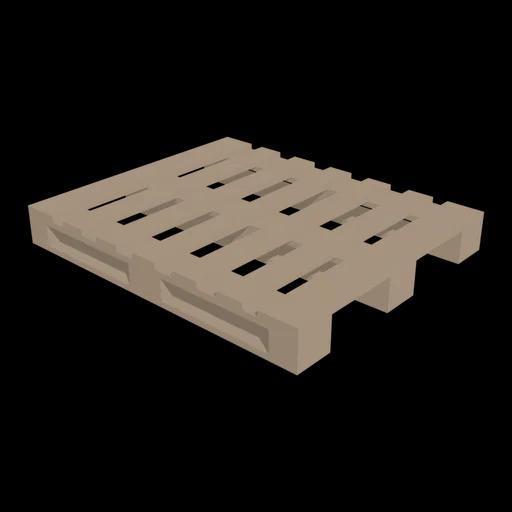
Wooden block pallet asset

Block pallet

Rigid · pallet.usd
Size
1.2 × 1.0 m
Mass
25 kg
Collider
22 boxes
Friction
0.5 static, 0.45 dynamic
Soft packaging

Deformable zip-lock bag

A deformable zip-lock bag with a working zipper, modeled as a film shell for home robots and lab kitting.

Foam, sponges and cushions

Deformable kitchen sponge

A deformable kitchen sponge with an optional scrub pad, modeled as an FEM soft foam body for dishwashing and cleaning robots.

Asset pipeline

  1. 01Inputphoto, video, prompt or GLB
  2. 02Meshwatertight, scaled to the reference
  3. 03Collisionconvex decomposition
  4. 04Physicsmass kg, friction μ, rigid or deformable
  5. 05USDone .usd, opens in Isaac Sim
Browse the asset catalog

03Generated environments

A whole scene from a prompt, images or a video.

When you need a believable place quickly rather than one specific site, we generate the entire environment: fully interactive, physics-aware, and delivered as a USD scene for Isaac Sim.

Modeled from a phone video
Generated from a text prompt
  1. 01

    Start from anything

    A written prompt, images or a short video.

  2. 02

    We generate the scene

    Floors, shelves, walls and the objects in between, with collision geometry and tuned physics so your robot can touch and move what it sees.

  3. 03

    Add variations

    Multiple variations of the same scene with a prompt, like a door open or a shelf full.

  4. 04

    It opens in Isaac Sim

    One physics-ready USD scene, ready for your robot model and your task.

Where will your robot head next? Tell us about the next site on your list and we’ll tell you what a twin of it would take.