Deformable strawberry
Harvesting
Produce and food
A deformable tomato in several sizes and ripeness levels, modeled as a soft FEM body for harvesting and packing robots.
Also called tomatoes or cherry tomato.
FEM soft body
Delivered as USD for NVIDIA Isaac Sim
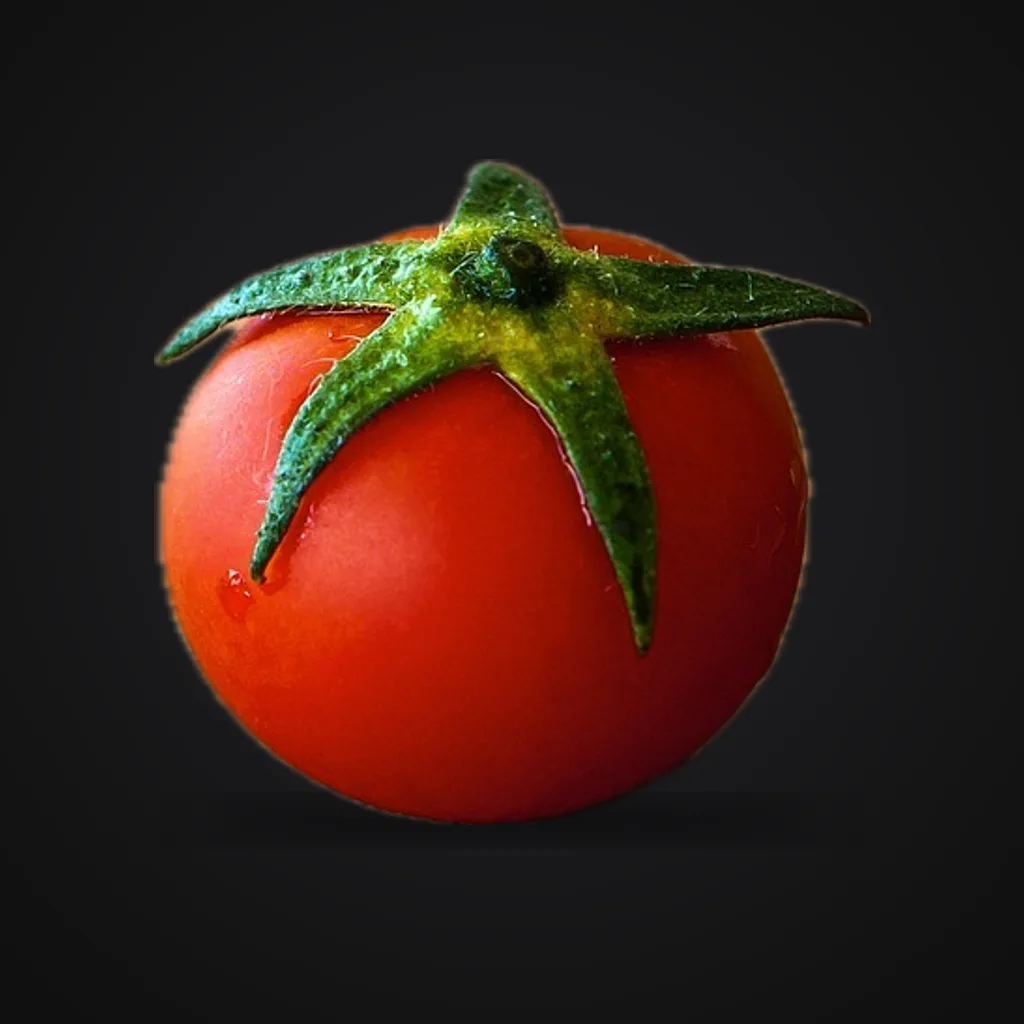
A tomato is a soft volume with a firmer skin and a stiff calyx. We model the flesh as a soft volume with stiffness set per ripeness, from firm green to soft red, so a gripper that is gentle enough for a ripe tomato is easy to tune.
Each set has several shapes and sizes. The asset flags the contact pressure above which a real tomato bruises, so a task can check grasps against it.
One USD file per variant, with the render mesh, the simulation geometry and a physics material bound to it. Every value is set and named, so you can open it in NVIDIA Isaac Sim and run your task, or read the numbers into your own solver from the material JSON.
Industries: Agriculture, Food, Retail
Questions
It ships as USD for NVIDIA Isaac Sim and Newton. We also deliver MJCF for MuJoCo and Genesis, a GLB mesh, and a JSON file with every material value.
Yes. Send us a sample, a drawing or a few photos and we set size, stiffness and friction to match your part.
Choose your simulator, format and variant, then tell us where to send it. We prepare the files and email them to you.
Harvesting
Packing into trays
Grocery packing
Harvesting